Search and Planning in AI
Search and planning represent possible states and actions to find a route toward a goal. Their usefulness depends on the model, costs, constraints, and evidence that actions work as expected.
출처
전체 수업 요약
A robot needs to reach a destination, and a timetable system needs to reach a valid assignment. Both can be understood as finding a route through possible states. Search explores those possibilities. Planning adds an explicit account of actions and their conditions and effects. These ideas predate modern language models and remain useful for understanding how a system can choose a sequence rather than merely produce a plausible description of one.
A search problem specifies an initial state, possible actions, resulting states, a goal test, and sometimes action costs. Different algorithms decide which possibilities to explore first. Breadth-first search expands shallow possibilities, while cost-based methods prioritize accumulated cost. Informed search uses a heuristic, an estimate that guides exploration toward promising states. A heuristic can save effort, but its properties and the search procedure determine what guarantees are justified.
For example, A-star search combines the cost already incurred with an estimate of the remaining cost. Under appropriate conditions, including suitable heuristic properties, it can find a least-cost solution. This is not a general promise that any AI-generated plan is optimal. A language model's confident preference is not automatically a valid heuristic, and a natural-language task may lack the precise state and action model needed for a formal guarantee.
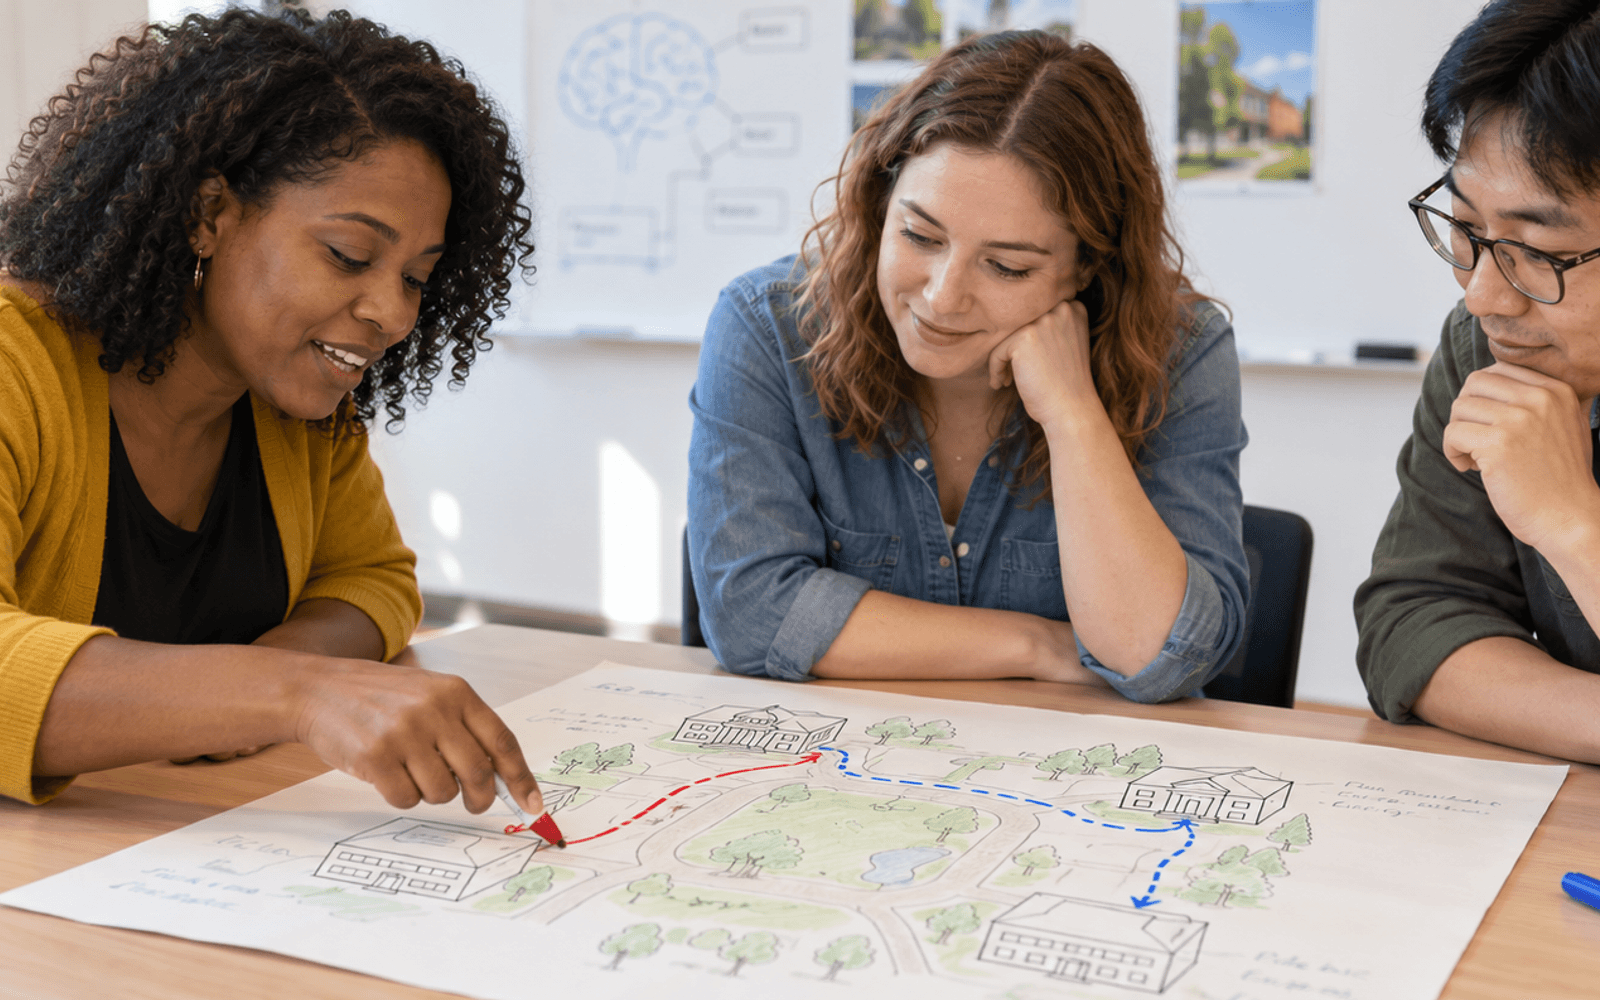
Imagine a campus navigation lesson using a fictional map. Learners seek a route from a library to a laboratory. They first minimize distance, then add a requirement to avoid stairs and allow time for a locked gate to open. The state may now need to include time as well as location. A shortest line on the map is no longer necessarily a feasible route. Students compare how the model changes the search and explain why an omitted constraint produces an unusable answer.
Planning in an educational assistant involves similar distinctions. Drafting a study schedule requires assumptions about available time, dependencies, and the effects of practice. Those effects are uncertain and cannot be treated like guaranteed moves on a board. A useful system monitors progress, checks whether actions occurred, and revises the plan when circumstances change. It should distinguish a proposed action from an executed action and a completed action from an achieved learning outcome.
A classroom activity can trace a small search tree and compare the number of states explored under two strategies. Follow this with a discussion of what the representation leaves out. Formal search is powerful when a task has a clear structure, but large or uncertain environments can make exact planning costly or inappropriate. Evaluate success against the actual goal, including safety and resource constraints. The educational lesson is that a plan is an argument about how actions change a situation, and that argument needs a trustworthy model and feedback from execution.


